

 基本信息
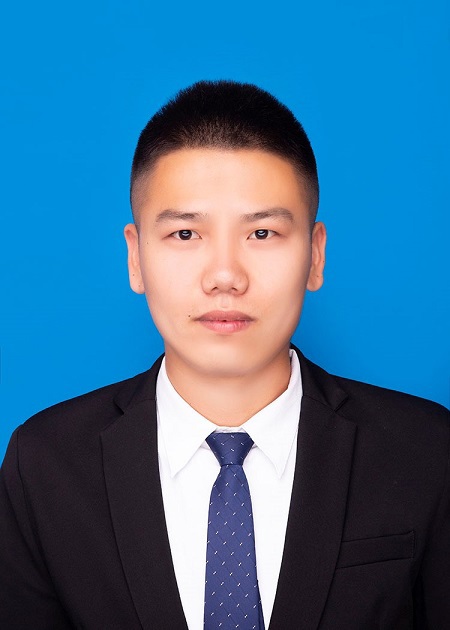
刘华,智能工程与智能制造学院讲师,博士学历。长期从事机器人运动规划、机电液系统控制等领域研究,在IEEE Transactions on Industrial Informatics、IEEE Robotics and Automation Letters等期刊发表论文5篇,授权发明专利1项,IEEE Transactions on Cybernetics期刊审稿人。Email:liuhua_0923@163.com。
 教育背景
2013-2017:内蒙古工业大学,获学士学位;
2017-2020:太原理工大学,获硕士学位;
2021-2026:中南大学,获博士学位;
 工作履历
2020-2021:江苏徐工工程机械研究院,液压控制工程师;
 教授课程
本科生课程:《单片机原理及应用》 研究领域
机器人运动规划:冗余机械臂、碰撞检测、避障规划、轨迹规划
机电液系统控制:伺服控制、液压系统控制、非线性控制
 科研项目
1.国家自然科学项目 “流量/压力双状态独立可控电液负载模拟新原理与方法”,参与。
2.企事业单位委托项目“凿岩台车钻凿炮孔智能化技术开发”,参与。
 学术成果
一、主要论文:
[1] Liu Hua, Wang Hengsheng, Guo Xinping, Wang Liang. A Reliable Learning-Based Approach for Self-Collision Checking on a Redundant Manipulator[J]. IEEE Transactions on Industrial Informatics, 2025, 21(5): 4169-4178.
[2] Liu Hua, Wang Hengsheng, Guo Xinping. Whole-body self-collision distance detection for a heavy-duty manipulator using neural networks[J]. IEEE Robotics and Automation Letters, 2024, 9(2): 1380-1387.
[3] 刘华,汪成文,郭新平.电液负载敏感位置伺服系统自抗扰控制方法[J].北京航空航天大学学报,2020,46(11):2131-2139.
[4] 汪成文,刘华,李标兵.自抗扰控制进出口独立调节系统性能研究[J].哈尔滨工程大学学报,2021,42(11):1679-1687.
[5] Guo Xinping, Wang Hengsheng, Liu Hua. Adaptive sliding mode control with disturbance estimation for hydraulic actuator systems and application to rock drilling jumbo[J]. Applied Mathematical Modelling, 2024, 136: 115637.